A different kind of deep dive.
Underwater robots, computer vision, and a whole lot of learning by doing.
It started with curiosity.
I started my robotics journey at twelve. Underwater robotics became one of the places where that curiosity turned into something real: hardware, software, and a robot that had to work beyond a laptop screen.
From a tether to autonomy.
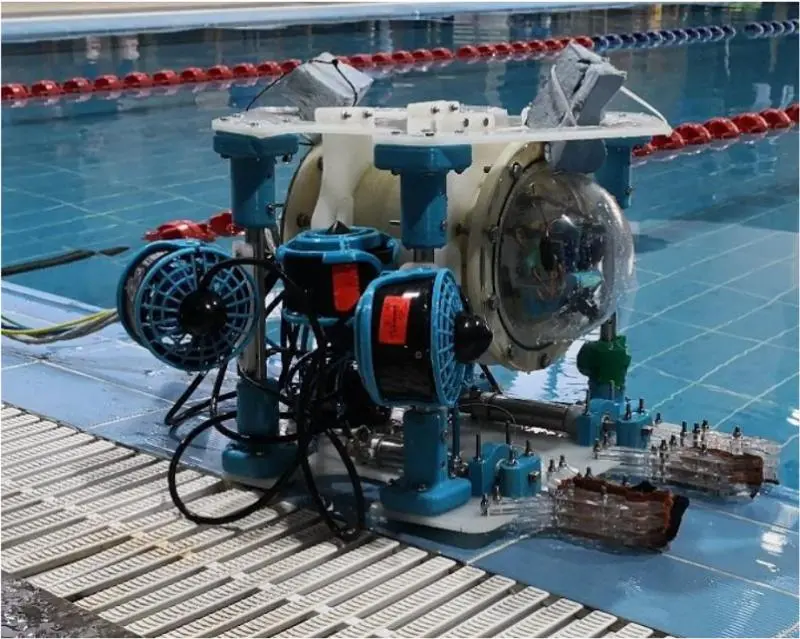
My underwater work spans Blue Marlin, a tethered remotely operated vehicle, and SWIFT, an autonomous underwater vehicle developed with Team Vortex for RoboSub 2021. They posed different challenges: helping a human pilot see and steer, and getting a robot to act on its own.
My part of the build.
For the MATE ROV team, I worked on computer vision and pilot software alongside a twenty-person team. Building together meant making software fit the physical robot, then testing it in the water.
The moments I kept.
Our RoboSub team placed fifth in 2021. I was also part of a MATE ROV finalist team in 2022. The best part of these competitions was bringing a machine to life with people who cared just as much as I did.
Curious about the details? Let’s talk